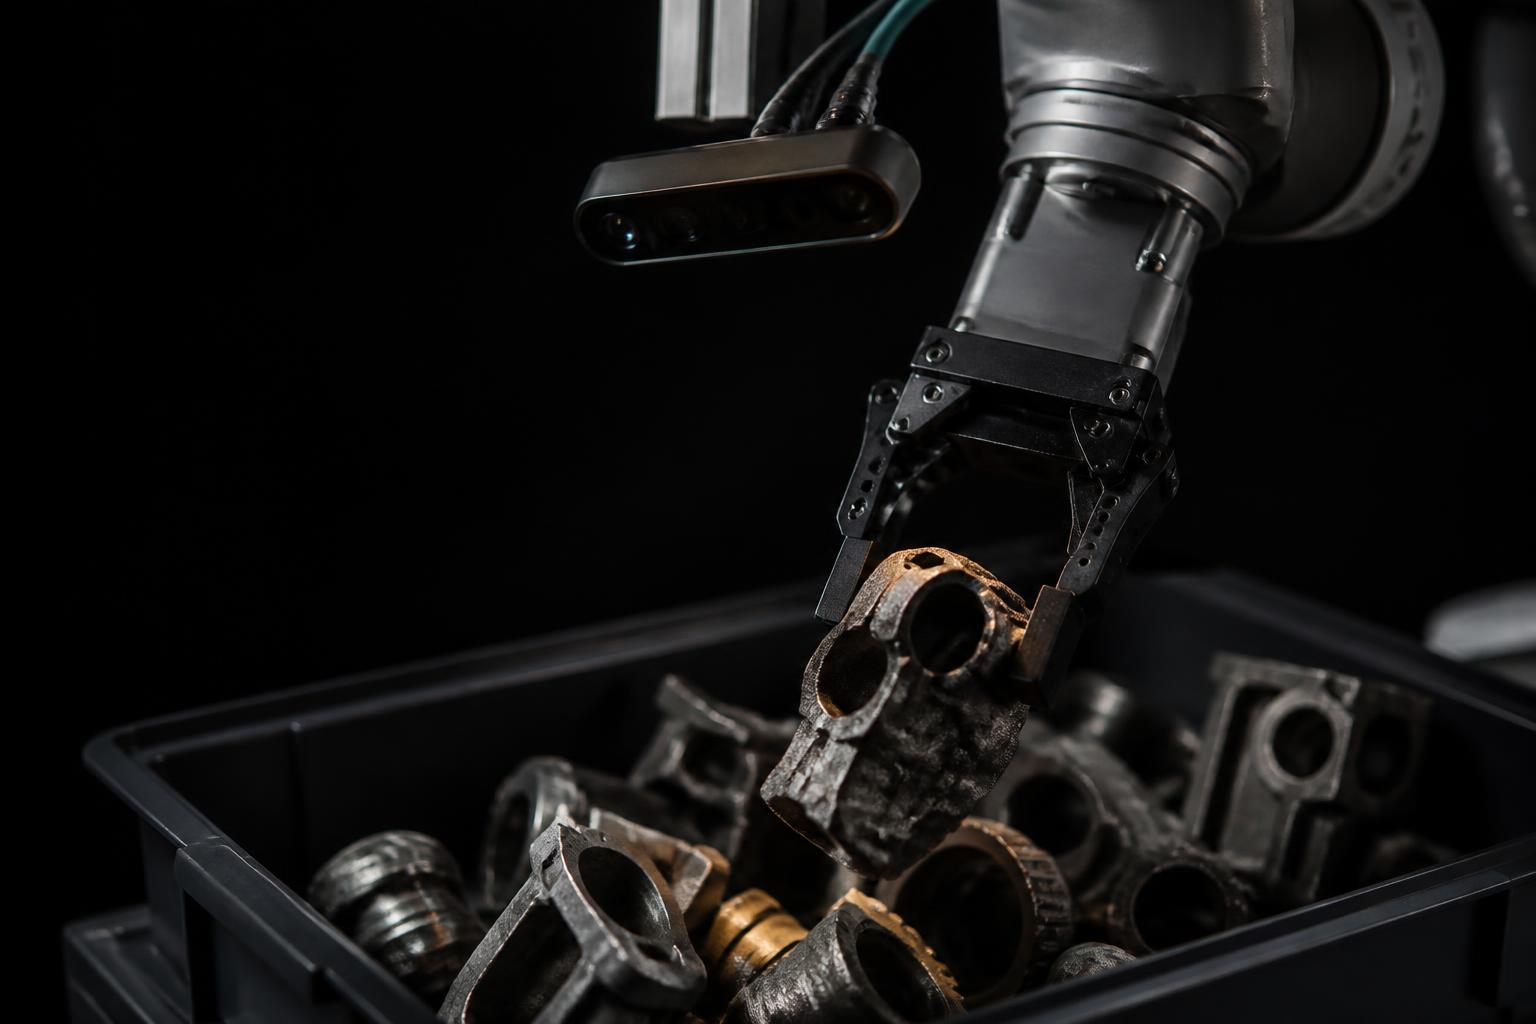
 PROJECT 001
General-Purpose Manipulation
A robotic manipulation system combining visual perception, grasp generation, motion planning and real-time control.
REAL ROBOTRGB-DVISIONMOTION PLANNINGROBOT LEARNINGCONTROL
View case studySystems built and iterated on real hardware. Each case study documents the problem, the approach and what remains open.
PROJECT 001A robotic manipulation system combining visual perception, grasp generation, motion planning and real-time control.
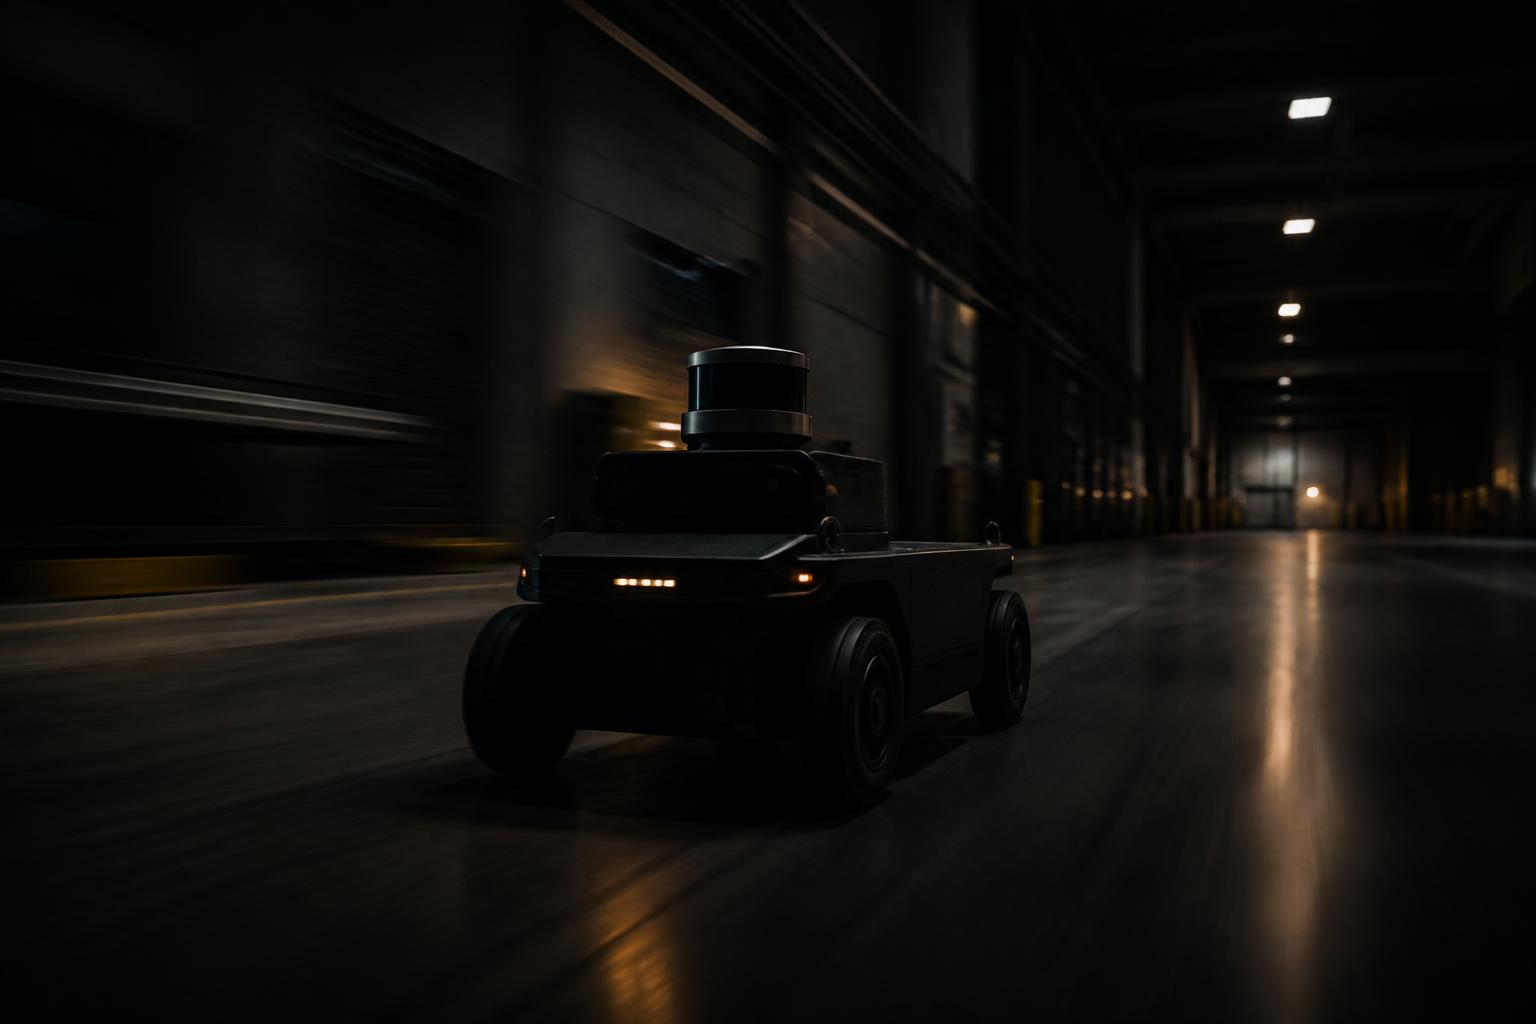 PROJECT 002
An intelligent mobile platform combining perception, localization, planning and velocity control for real-world navigation.
Whether you are exploring a new robotic application, looking to automate a physical process, or developing the next generation of intelligent machines, let's build it.